Quick Answer
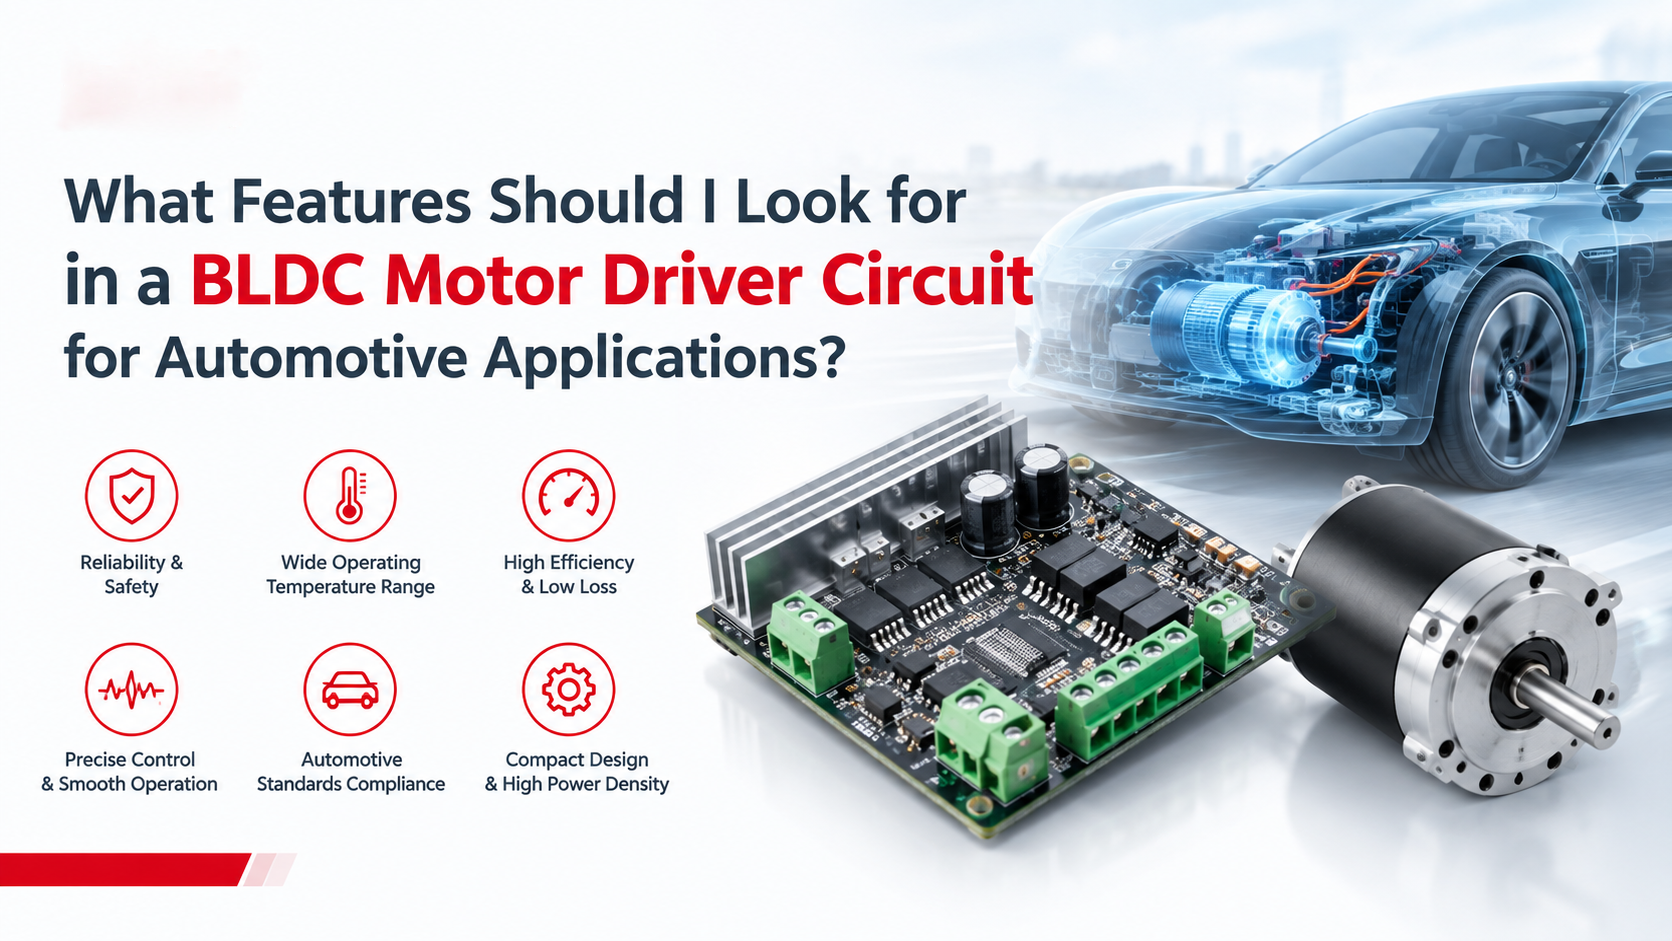
When selecting a BLDC motor driver circuit for automotive applications, engineers should evaluate the complete electrical and mechanical operating requirements rather than looking only at nominal voltage or rated current. Key features include compatible DC voltage, sufficient continuous and peak current, three-phase commutation, Hall sensor or encoder feedback, speed and torque control, current monitoring, overcurrent and thermal protection, reliable startup, low-noise operation, and compatibility with the motor’s winding and load characteristics.
For customized automotive motion systems, the motor and driver should also be evaluated together because the required voltage, torque, speed, feedback method, gearbox ratio, and control strategy directly affect driver selection.
Match the BLDC Motor Driver to the Motor Specifications
The first step in selecting a BLDC motor driver circuit is to define the motor’s complete operating range.
A motor driver should be matched according to:
| Parameter | What Engineers Should Check |
| Supply voltage | Nominal and operating voltage range |
| Continuous current | Current required during normal operation |
| Peak current | Current required during startup and acceleration |
| Speed | Continuous and maximum operating RPM |
| Torque | Continuous and peak torque |
| Feedback | Hall sensor, encoder, or sensorless |
| Control | Speed, torque, position, or closed-loop control |
| Motor size | Motor diameter and installation envelope |
| Gearbox | Required reduction ratio and output torque |
| Environment | Temperature, vibration, humidity, and dust |
United Motion Inc. provides BLDC motors ranging from 28 mm to 110 mm, with configurable motor specifications and options including Hall sensors, encoders, gearboxes, and integrated drivers.
This makes it possible to develop the motor and driver as a complete motion-control solution instead of treating the motor and controller as two unrelated components.
Check Continuous and Peak Current Capability
Current capability is one of the most important parameters when selecting a BLDC driver.
The driver’s continuous current rating should be sufficient for the motor’s normal operating current, while its peak-current capability should accommodate temporary conditions such as startup, acceleration, sudden load changes, or short-duration high-torque operation.
For example, if an automotive actuator normally operates at 6 A but requires 15 A during acceleration, selecting a driver based only on the 6 A continuous requirement could result in startup problems, current limiting, overheating, or insufficient acceleration torque.
Engineers should therefore evaluate:
Continuous Current Requirement → Normal operating load
Peak Current Requirement → Acceleration + transient load
The actual current requirement should be calculated from the motor’s torque-speed curve and the application’s mechanical load rather than estimated from the motor’s nominal specifications alone.
Look for Accurate Motor Feedback
Rotor-position feedback is critical because a BLDC motor driver must determine when and how to energize the three motor phases.
Hall Sensor Feedback
Hall sensors provide rotor-position information that allows the controller to perform electronic commutation.
They are particularly useful when the application requires reliable startup and stable operation at low speed.
United Motion’s BLDC motor solutions can be configured with Hall sensors, allowing the motor and driver to be designed around a defined commutation strategy.
Encoder Feedback
An encoder provides more detailed rotor-position information and can be used when the application requires more precise speed or position control.
Encoder feedback can be especially useful for automotive actuators and motion systems where the controller needs accurate information about shaft position.
Sensorless Control
Sensorless BLDC control can eliminate physical position sensors and reduce wiring and component count, but the control algorithm must estimate rotor position from electrical characteristics.
For applications requiring predictable low-speed startup or precise motion, engineers should carefully compare sensorless control with Hall or encoder feedback before finalizing the architecture.
Consider FOC for Smooth and Precise Motion
Another important feature is the control algorithm used by the BLDC motor driver.
Traditional six-step commutation is suitable for many BLDC applications, while Field-Oriented Control (FOC) can provide more sophisticated control of motor current, torque, and speed.
FOC can be considered when the application requires:
- Smooth motor operation
- Low-speed stability
- Accurate speed control
- Reduced torque ripple
- Low acoustic noise
- Fast dynamic response
- More precise torque control
For automotive motion systems where noise, vibration, and smooth movement are important, the motor, feedback device, driver, and control algorithm should be optimized together rather than selected independently.
Select a Driver With Appropriate Protection
Automotive environments can expose motor electronics to changing loads, electrical disturbances, and high operating temperatures, making protection functions an important part of the BLDC driver circuit.
A practical BLDC driver should consider:
| Protection Function | Purpose |
| Overcurrent protection | Limits excessive motor or phase current |
| Short-circuit protection | Helps protect the power stage |
| Overtemperature protection | Prevents excessive thermal stress |
| Undervoltage protection | Maintains reliable driver operation |
| Overvoltage protection | Protects electronic components |
| Stall detection | Identifies abnormal motor loading |
| Phase-loss detection | Detects motor or connection problems |
Protection should be evaluated together with the motor’s actual operating conditions because an oversized protection threshold may not adequately protect the system, while an excessively low threshold can cause unnecessary shutdowns during normal acceleration.
Pay Attention to Thermal Management
A BLDC motor driver converts electrical power into controlled three-phase motor current, and some energy is inevitably dissipated as heat.
Driver thermal performance depends on several factors, including:
- Motor current
- MOSFET resistance
- Switching frequency
- PWM strategy
- PCB design
- Enclosure size
- Ambient temperature
- Duty cycle
- Motor load
A simplified conduction-loss relationship is:
P = I² × R
For example, if a power-stage resistance is 10 mΩ and the current is 15 A:
P = 15² × 0.01 = 2.25 W
This simplified calculation does not include switching losses or other sources of heat, but it demonstrates why current has a significant effect on driver temperature.
For compact automotive systems, thermal design should therefore be evaluated at the same time as electrical performance.
Evaluate PWM and Speed-Control Requirements
PWM control is commonly used to regulate the effective voltage and power supplied to the motor.
When selecting the BLDC driver, engineers should consider:
- PWM frequency
- Speed-control range
- Acceleration and deceleration behavior
- Minimum stable speed
- Maximum operating speed
- Response to sudden load changes
- Speed-feedback resolution
The required control method depends heavily on the application.
For example, a cooling fan may prioritize a wide speed range and efficient continuous operation, while an automotive actuator may place greater emphasis on controlled acceleration, repeatable positioning, low noise, and rapid response.
Consider Motor and Gearbox Integration
The BLDC motor itself is only one part of the motion system.
When higher output torque is required at a lower mechanical speed, a gearbox can be integrated with the BLDC motor.
United Motion Inc. offers BLDC solutions that can be combined with gearboxes and encoders, allowing engineers to configure the motor, transmission, feedback, and driver around the final mechanical requirements.
For example:
Motor Speed → Gear Reduction → Output Speed
Motor Torque → Gear Reduction → Increased Output Torque
This approach is useful when the application requires compact dimensions while maintaining sufficient output torque.
BLDC Motor Driver Features Comparison
| Feature | Basic Driver | Automotive Motion System |
| Three-phase control | Required | Required |
| PWM speed control | Common | Common |
| Hall sensor | Optional | Application dependent |
| Encoder | Optional | Useful for precise motion |
| FOC | Optional | Useful for smooth control |
| Current monitoring | Basic | Recommended |
| Overcurrent protection | Recommended | Important |
| Thermal protection | Recommended | Important |
| Stall detection | Optional | Useful |
| Gearbox integration | Optional | Application dependent |
| Custom winding | Limited | Useful for OEM design |
| Integrated driver | Optional | Useful for compact systems |
Common BLDC Driver Problems and Solutions
| Problem | Possible Cause | Recommended Check |
| Motor does not start | Incorrect phase or Hall sequence | Verify motor and feedback wiring |
| High startup current | Excessive load or incorrect commutation | Check load and commutation settings |
| Motor overheats | Excessive current or insufficient cooling | Measure current and temperature |
| Speed fluctuates | Incorrect feedback or control parameters | Check Hall/encoder signals |
| Driver shuts down | Thermal or current protection | Check fault conditions |
| Motor stalls | Insufficient torque | Check torque-speed requirements |
| Excessive noise | Control or mechanical resonance | Check PWM, FOC parameters, and load |
| Low output torque | Incorrect motor/gearbox selection | Recalculate torque and speed requirements |
Step-by-Step BLDC Driver Selection
Step 1: Define the power supply
Determine the actual operating voltage and acceptable voltage range before selecting the driver.
Step 2: Calculate the load
Determine continuous torque, peak torque, acceleration requirements, and maximum speed.
Step 3: Calculate current
Use the motor’s torque and current characteristics to determine continuous and peak current requirements.
Step 4: Select feedback
Choose Hall sensors, encoder feedback, or sensorless control according to startup, speed, and positioning requirements.
Step 5: Select the control method
Determine whether conventional BLDC commutation or FOC is more appropriate for the required speed stability, torque control, and noise performance.
Step 6: Evaluate protection
Check overcurrent, short-circuit, thermal, voltage, stall, and phase-loss protection.
Step 7: Evaluate thermal performance
Verify that the driver can dissipate heat under the application’s actual current, duty cycle, and ambient-temperature conditions.
Step 8: Integrate the complete motion system
Evaluate the BLDC motor, driver, encoder or Hall sensor, and gearbox as a complete system before finalizing the design.
Common Engineering Mistakes
One common mistake is selecting a BLDC driver solely according to the motor’s nominal voltage, while ignoring peak current, startup torque, operating temperature, and transient loading.
Another is choosing a driver with sufficient continuous current but insufficient peak-current capability, which can cause problems during acceleration or high-load operation.
A third mistake is treating the motor and driver as independent components. Motor winding configuration, Hall-sensor position, encoder specifications, gearbox ratio, torque requirements, and control parameters all influence the final driver configuration.
For OEM applications, working with a motor supplier that can provide custom BLDC motors, Hall sensors, encoders, gearboxes, and integrated driver solutions can simplify system matching and prototype development.
FAQ
What is a BLDC motor driver circuit?
A BLDC motor driver circuit is the electronic control system that supplies and switches current to the three phases of a brushless DC motor while controlling its speed, torque, and operating behavior.
What features should an automotive BLDC motor driver have?
Important features include suitable voltage and current ratings, three-phase control, PWM regulation, rotor-position feedback, current monitoring, electrical protection, thermal protection, and appropriate speed or torque-control functions.
Does a BLDC motor need Hall sensors?
Not always. A BLDC motor can use Hall sensors, an encoder, or sensorless control depending on the application’s requirements for startup, low-speed operation, speed control, and position feedback.
Is FOC suitable for BLDC automotive applications?
FOC can be suitable when an application requires smooth operation, precise speed or torque control, reduced torque ripple, and good low-speed performance.
Can the BLDC motor and driver be customized together?
Yes. United Motion Inc. provides customizable BLDC motor solutions with options including different motor sizes, windings, Hall sensors, encoders, gearboxes, and driver integration.
What BLDC motor sizes are available from United Motion Inc.?
United Motion Inc. offers BLDC motors covering approximately 28 mm to 110 mm frame sizes, with configurations for different voltage, speed, torque, feedback, gearbox, and driver requirements.
Related blog: What Are the Fundamental Principles of a BLDC Motor Driver Circuit?